solarian-gripper1
BetaA slim parallel gripper with a wrist camera, driven by a single servo.
solarian-dev/solarian-gripper1
- Aperture
- 0–85 mm
- Actuators
- 1
- Wrist camera
- Pi HQ
Loading MuJoCo model…
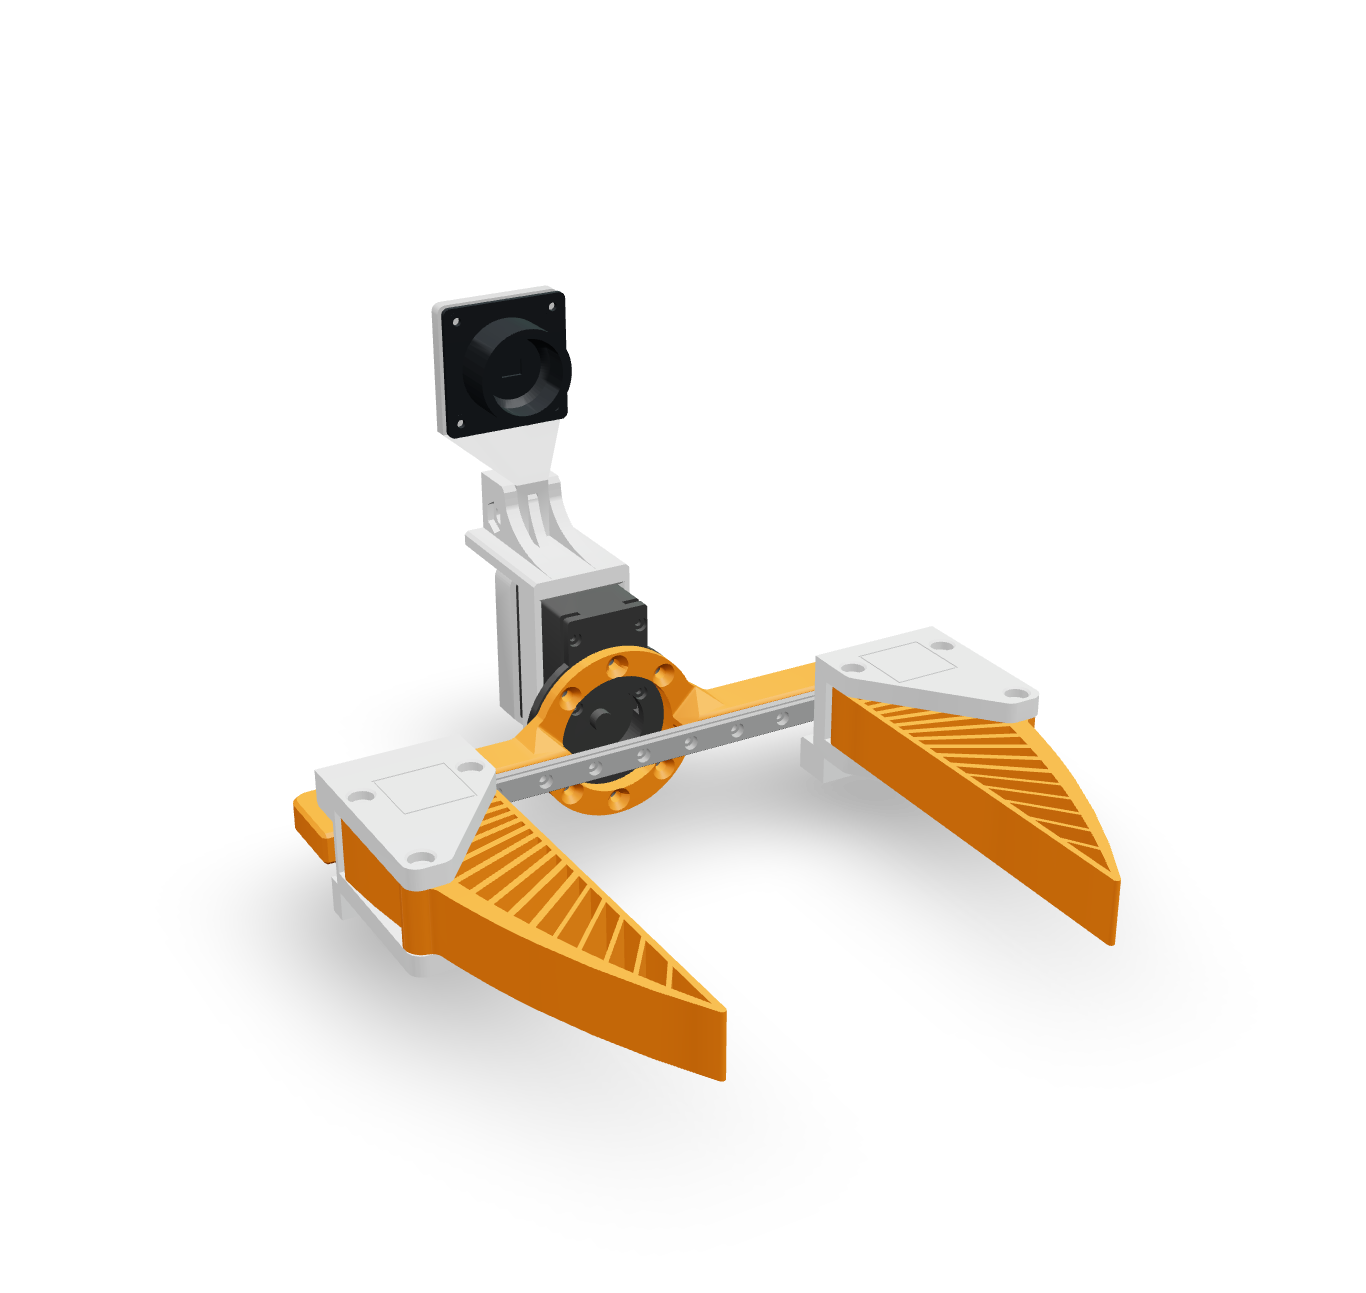
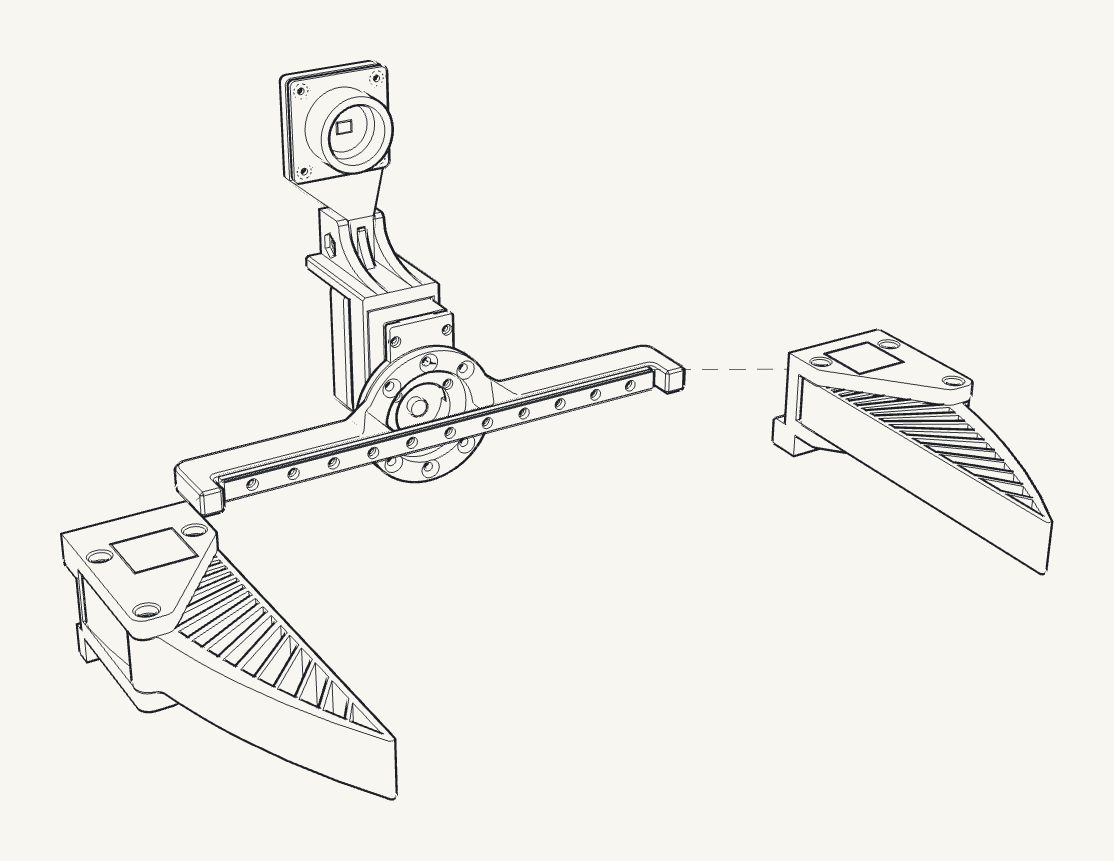
solarian-gripper1 is a two-finger parallel gripper designed with reference to the open Universal Manipulation Interface (UMI) project. It is not affiliated with UMI or its authors. One servo drives a rack along a rail and both carriages move symmetrically, so you command it by finger aperture in millimetres. A Raspberry Pi HQ camera sits on the wrist for policies that learn from the gripper's point of view. It ships in a Feetech STS variant and a Robstride L7 variant with the same finger kinematics.
- Builds on
- Universal Manipulation Interface ↗
- License
- To be announced
- Category
- Gripper