Solarian
Solarian
  • Plugin Directory
  • Hardware Directory
  • Solarian Base
  • Documentation
Sign in
  • API
  • Documentation
  • Support
  • Get Started

    • Introduction
    • Overview
    • Installation
    • Creating a Project
  • Tutorials

    • Tutorials
    • 1. Gentle intro to Robotics
    • 2. Your first Robot
    • 3. The real robot
    • 4. Robot skills
    • 5. Train a skill
  • Core Concepts

    • Robot
    • Modules
    • Observations
    • Controller
    • Actions
    • Skills
    • Server
    • Events
    • Services
    • Project Settings
    • Config Files
    • Calibration
    • Scheduling Waypoints
    • Inverse Kinematics
    • Latency & Synchronization
    • Recording
    • Datasets
    • Simulation
    • Plugins
  • CLI

    • Global flags
    • Project commands
    • Robot commands
    • Controller commands
    • Recording & replay
    • Training & data
    • Utility commands
    • Custom commands
  • AI

    • AI Overview
    • AI Controller
    • Policies
    • Training
    • Experiment Tracking
  • Hardware

    • Hardware Directory
      • LUMI collector
      • SO-106
      • UMI-slim
  • Solarian Base

    • Overview
    • Quick Start
    • Getting Started
    • Projects & Datasets
    • Deployments & Secrets
    • Training & Runs
    • Services, Policies & Models
    • Robots & Controller
    • CLI Reference
    • Self-hosting
  • Glossary

    • Glossary
  • Sign in

Hardware Directory

Open-source robots that run on Solarian — arms, grippers, mobile bases and data collectors. Every entry ships a MuJoCo model, so you can spin it, pose it and simulate it right here before you print a single part.
AllArmGripperData collector
Add your hardware
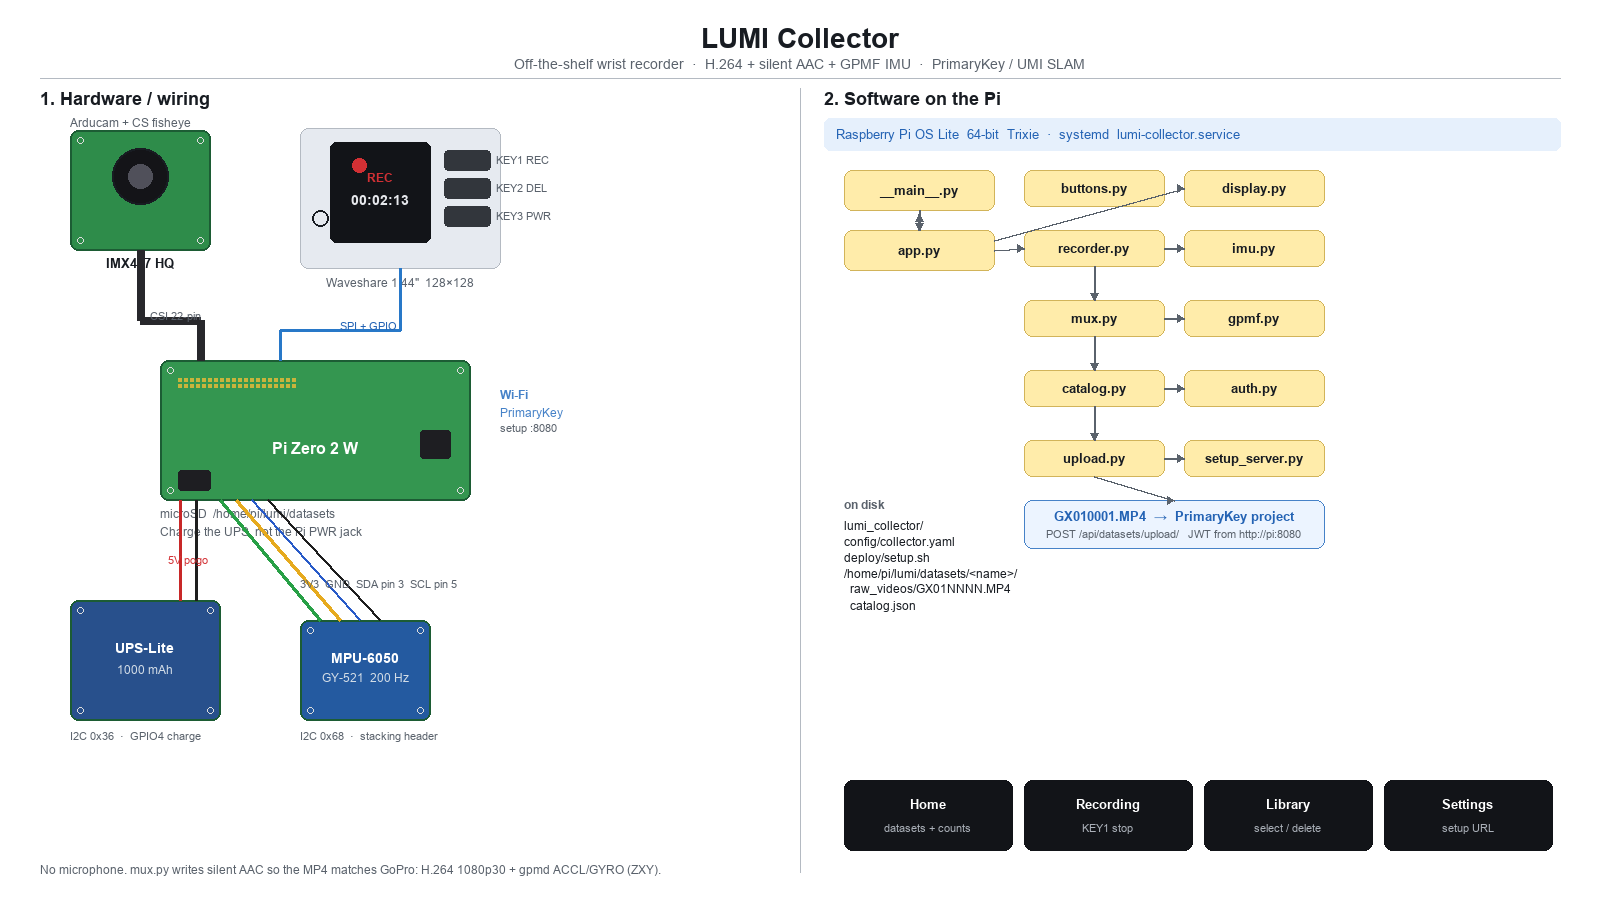
Wiring and the Python modules that run on the Pi
Data collectorPrototype

LUMI collector

A handheld, GoPro-shaped recorder for collecting UMI-style demonstrations.

Video
1080p30
IMU
200 Hz
Runtime
30–45 min
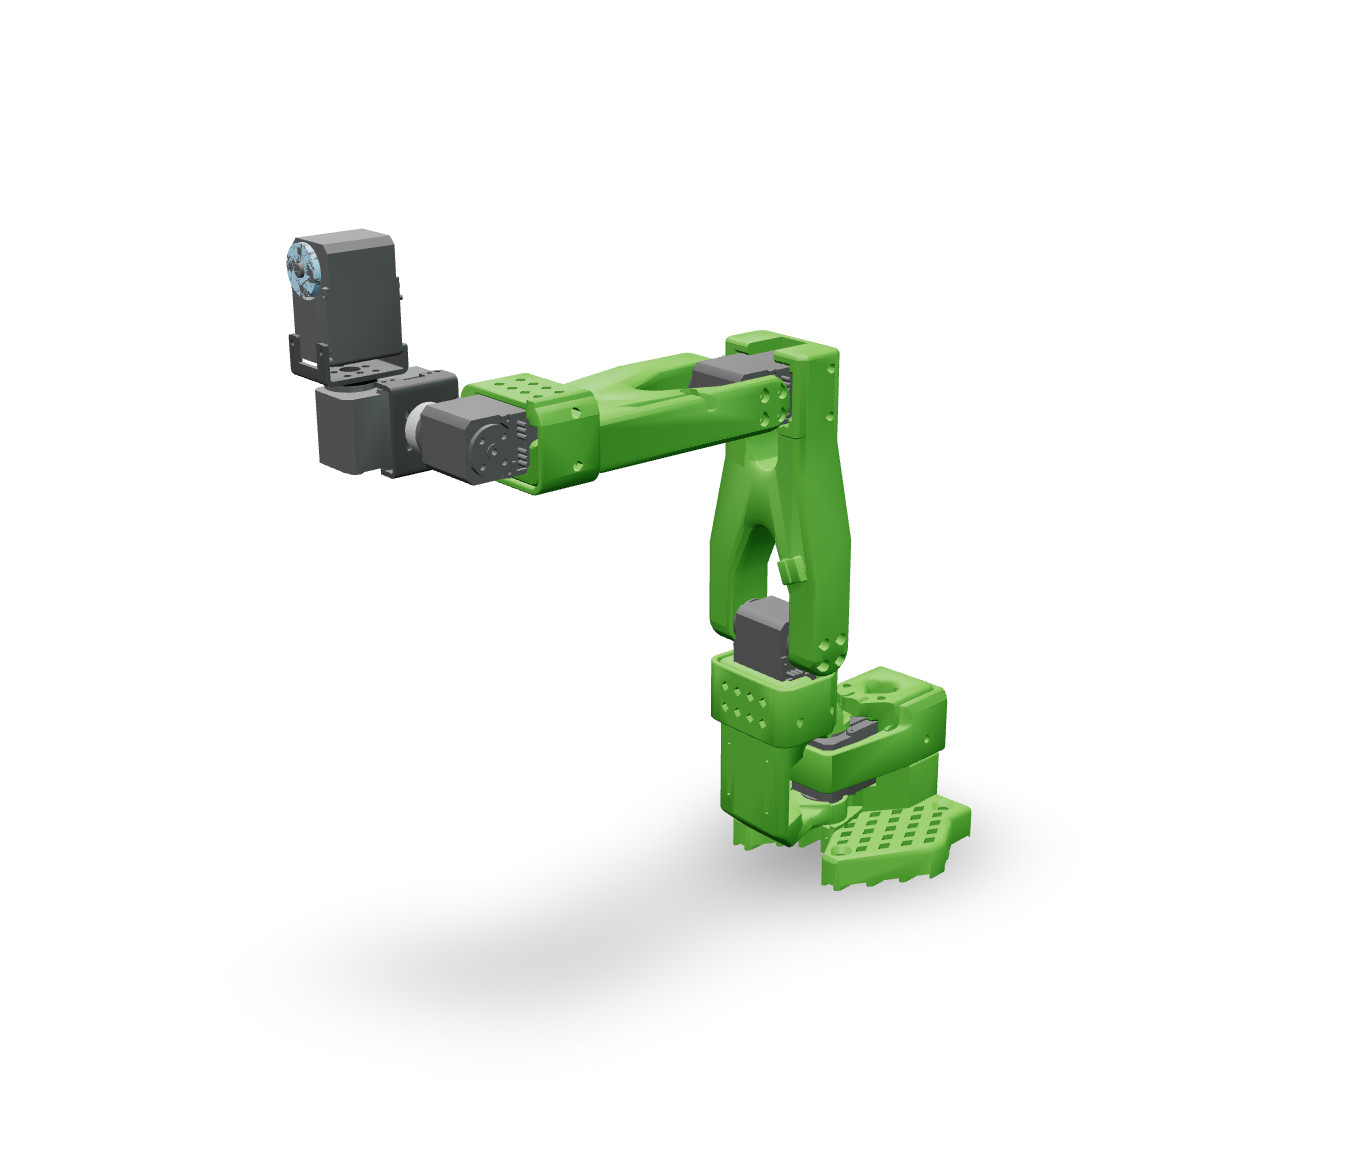
SO-106, rendered from its MuJoCo model
ArmBeta
3D · 6 joints

SO-106

A 6-DOF desktop arm built from Feetech serial-bus servos.

Degrees of freedom
6
Servos
Feetech STS
Control rate
90 Hz
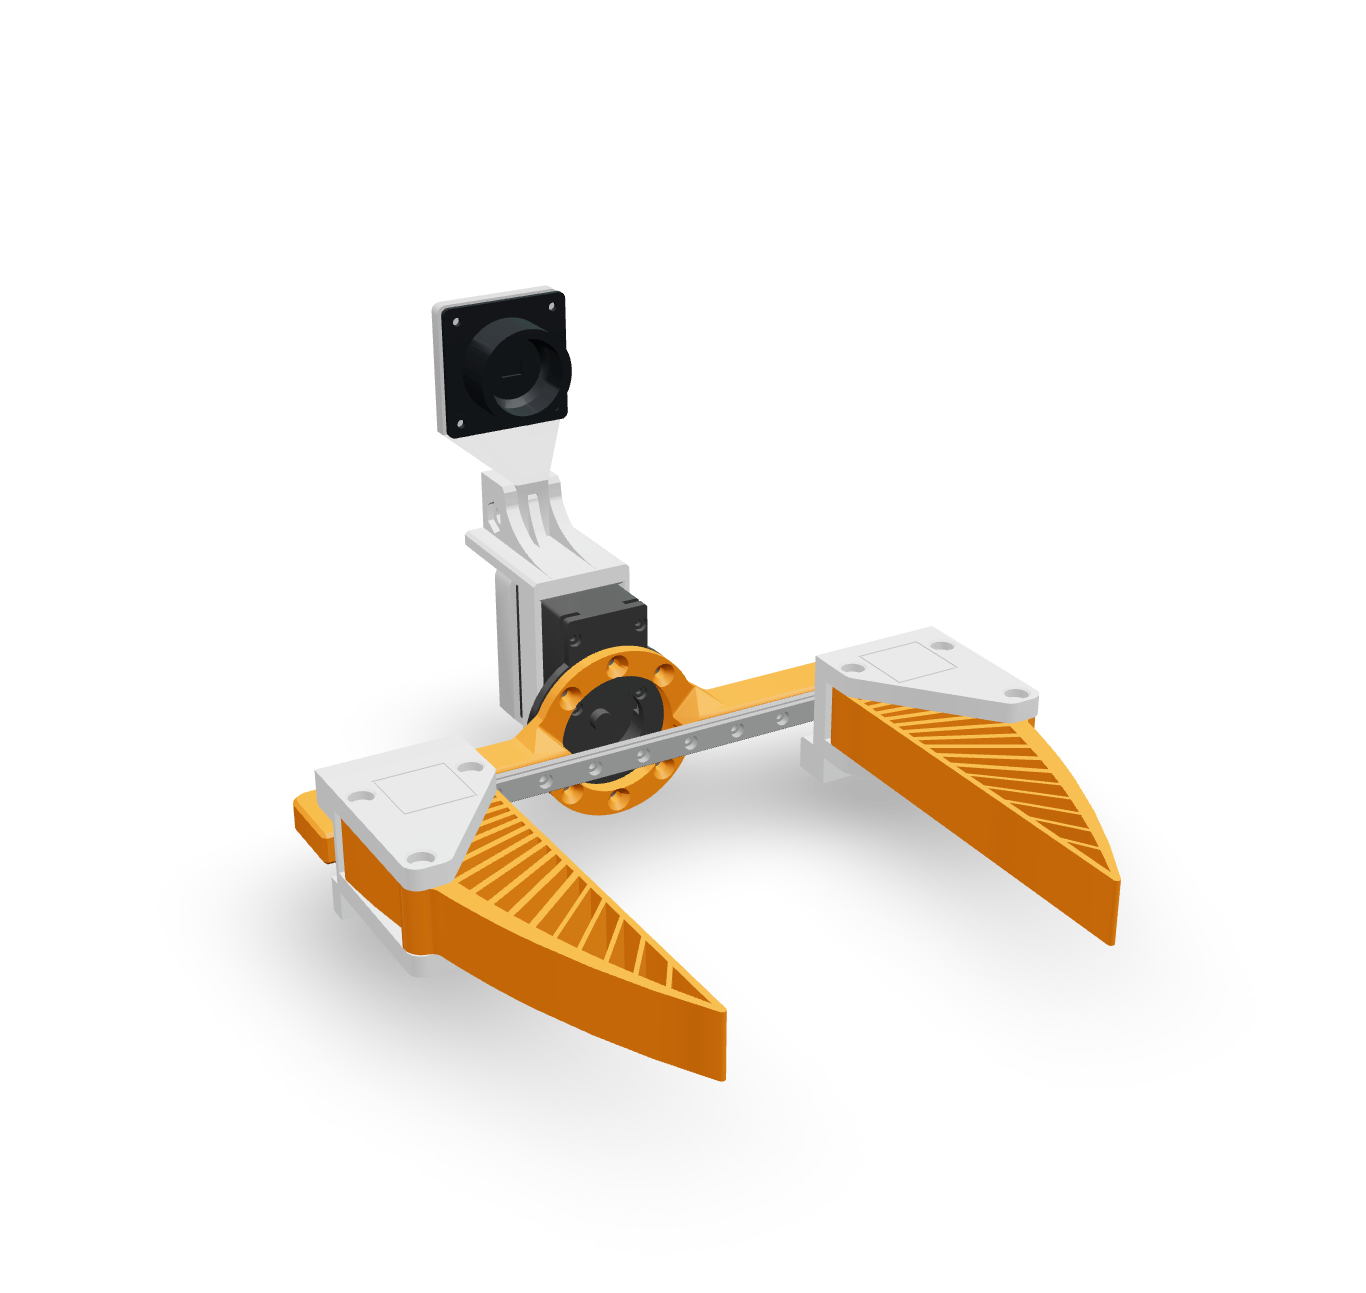
UMI-slim, rendered from its MuJoCo model
GripperBeta
3D · 2 joints

UMI-slim

A slim parallel gripper with a wrist camera, driven by a single servo.

Aperture
0–85 mm
Actuators
1
Wrist camera
Pi HQ
PreviousExperiment Tracking
NextOverview

© Copyright 2026. All rights reserved.

Follow us on XFollow us on GitHubJoin our Discord server